 Season completed
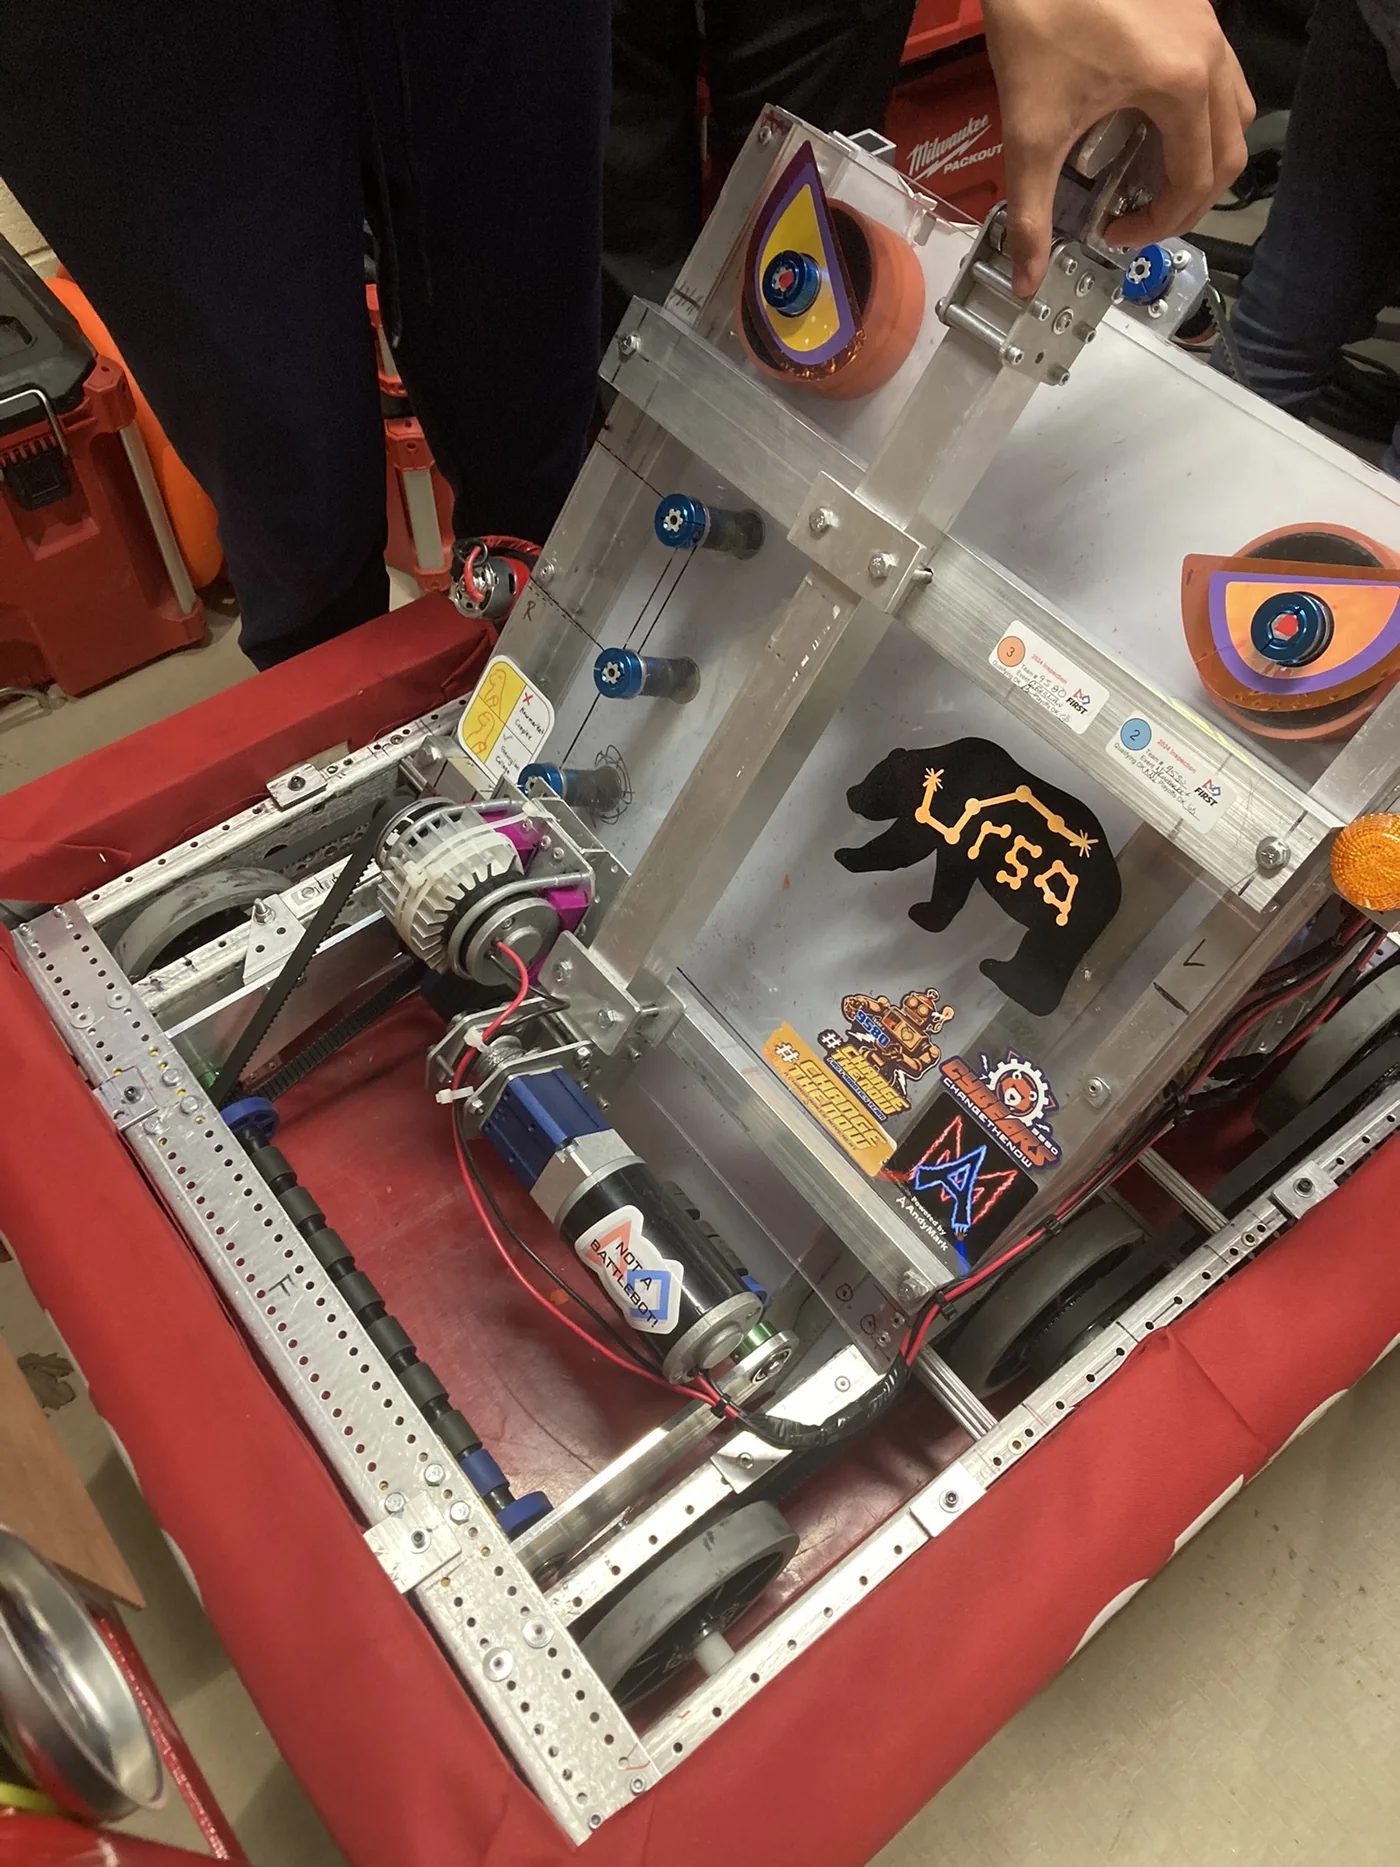
FRC Team 9580
Captaining a rookie FRC team, developing the under-bumper intake, and contributing substantial mechanical fabrication and electrical work.
Three wheels. Translation and rotation together.
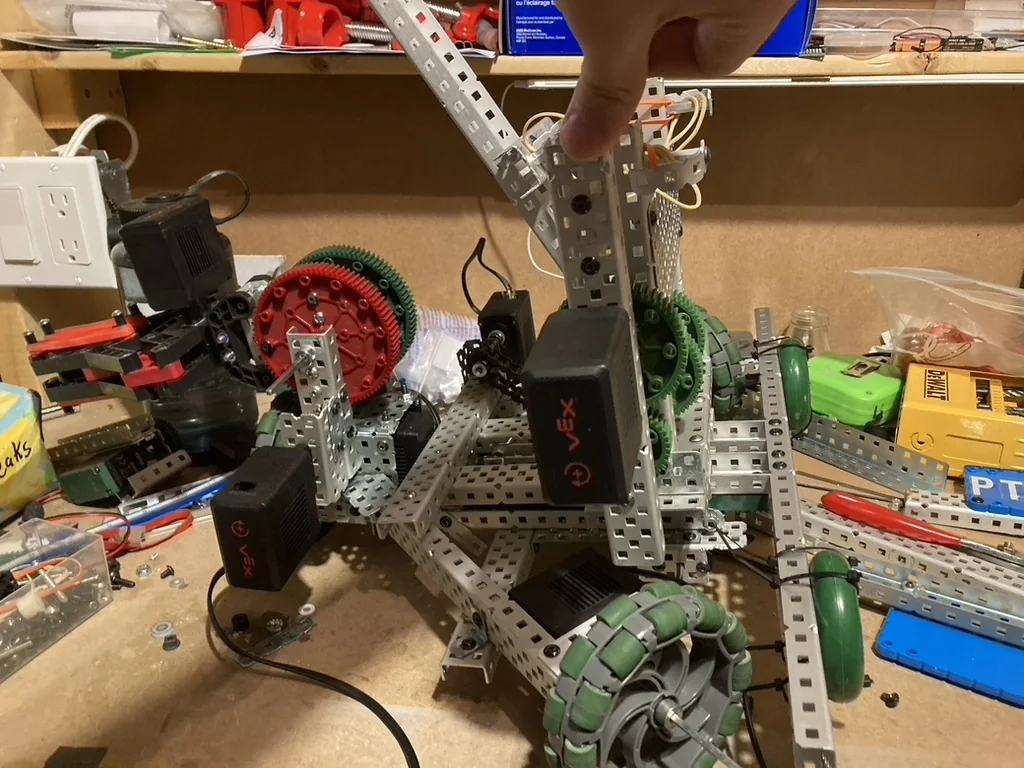
Independently arriving at a kiwi-drive layout and writing its movement controls, including simultaneous translation and turning.
I wanted omnidirectional motion without the extra drive wheels and motors of the layouts I knew. I had not seen a kiwi drive at the time, so I worked through a three-wheel arrangement myself.
The controls combined each wheel’s contribution to the desired movement, with adjustable wheel offsets. They could command movement in any direction and add turning at the same time.
The result was an independently developed implementation of an established drive type. What mattered to me was arriving at the idea through my own reasoning and seeing it work on a physical robot.
The robot also had a catapult, an extending front ram and a rear climber. A teammate contributed to the catapult; I did most of the overall build and integration.
We took part in smaller inter-school competitions. The project remains a favourite example of the enjoyment I get from building something I have worked out for myself.
The robot could combine translation and rotation. Developing the layout and controls myself helped me understand how the individual wheel motions combine into the movement of the whole robot.
Season completedCaptaining a rookie FRC team, developing the under-bumper intake, and contributing substantial mechanical fabrication and electrical work.
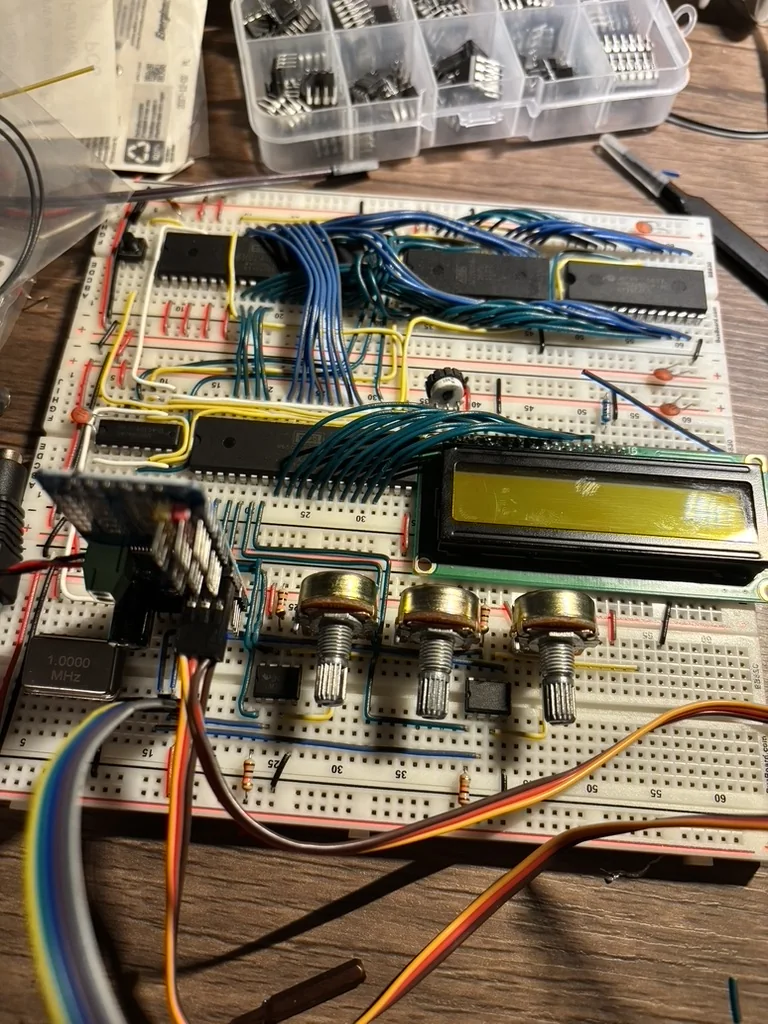 Exploratory prototype
A Ben Eater-based computer extended with joystick and servo interfaces, plus independently derived arm kinematics calculated in assembly.
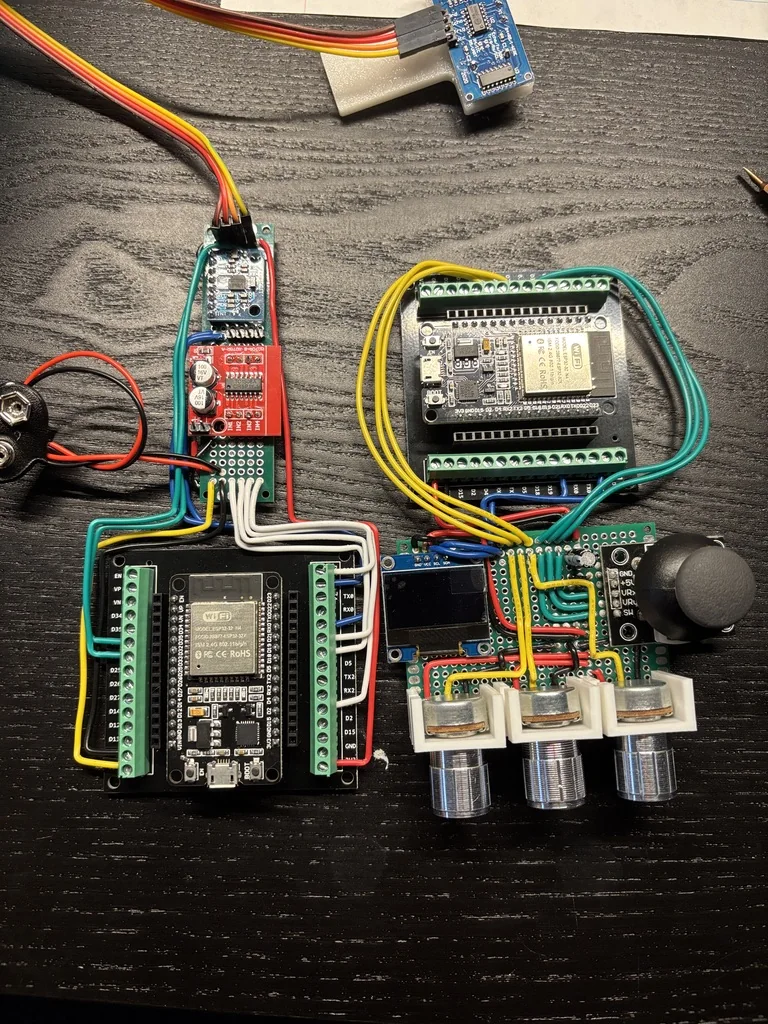 Teaching prototype built
A heading-controlled robot and live PID-tuning remote, developed as a reference for a 14-week WE FIRST workshop series.