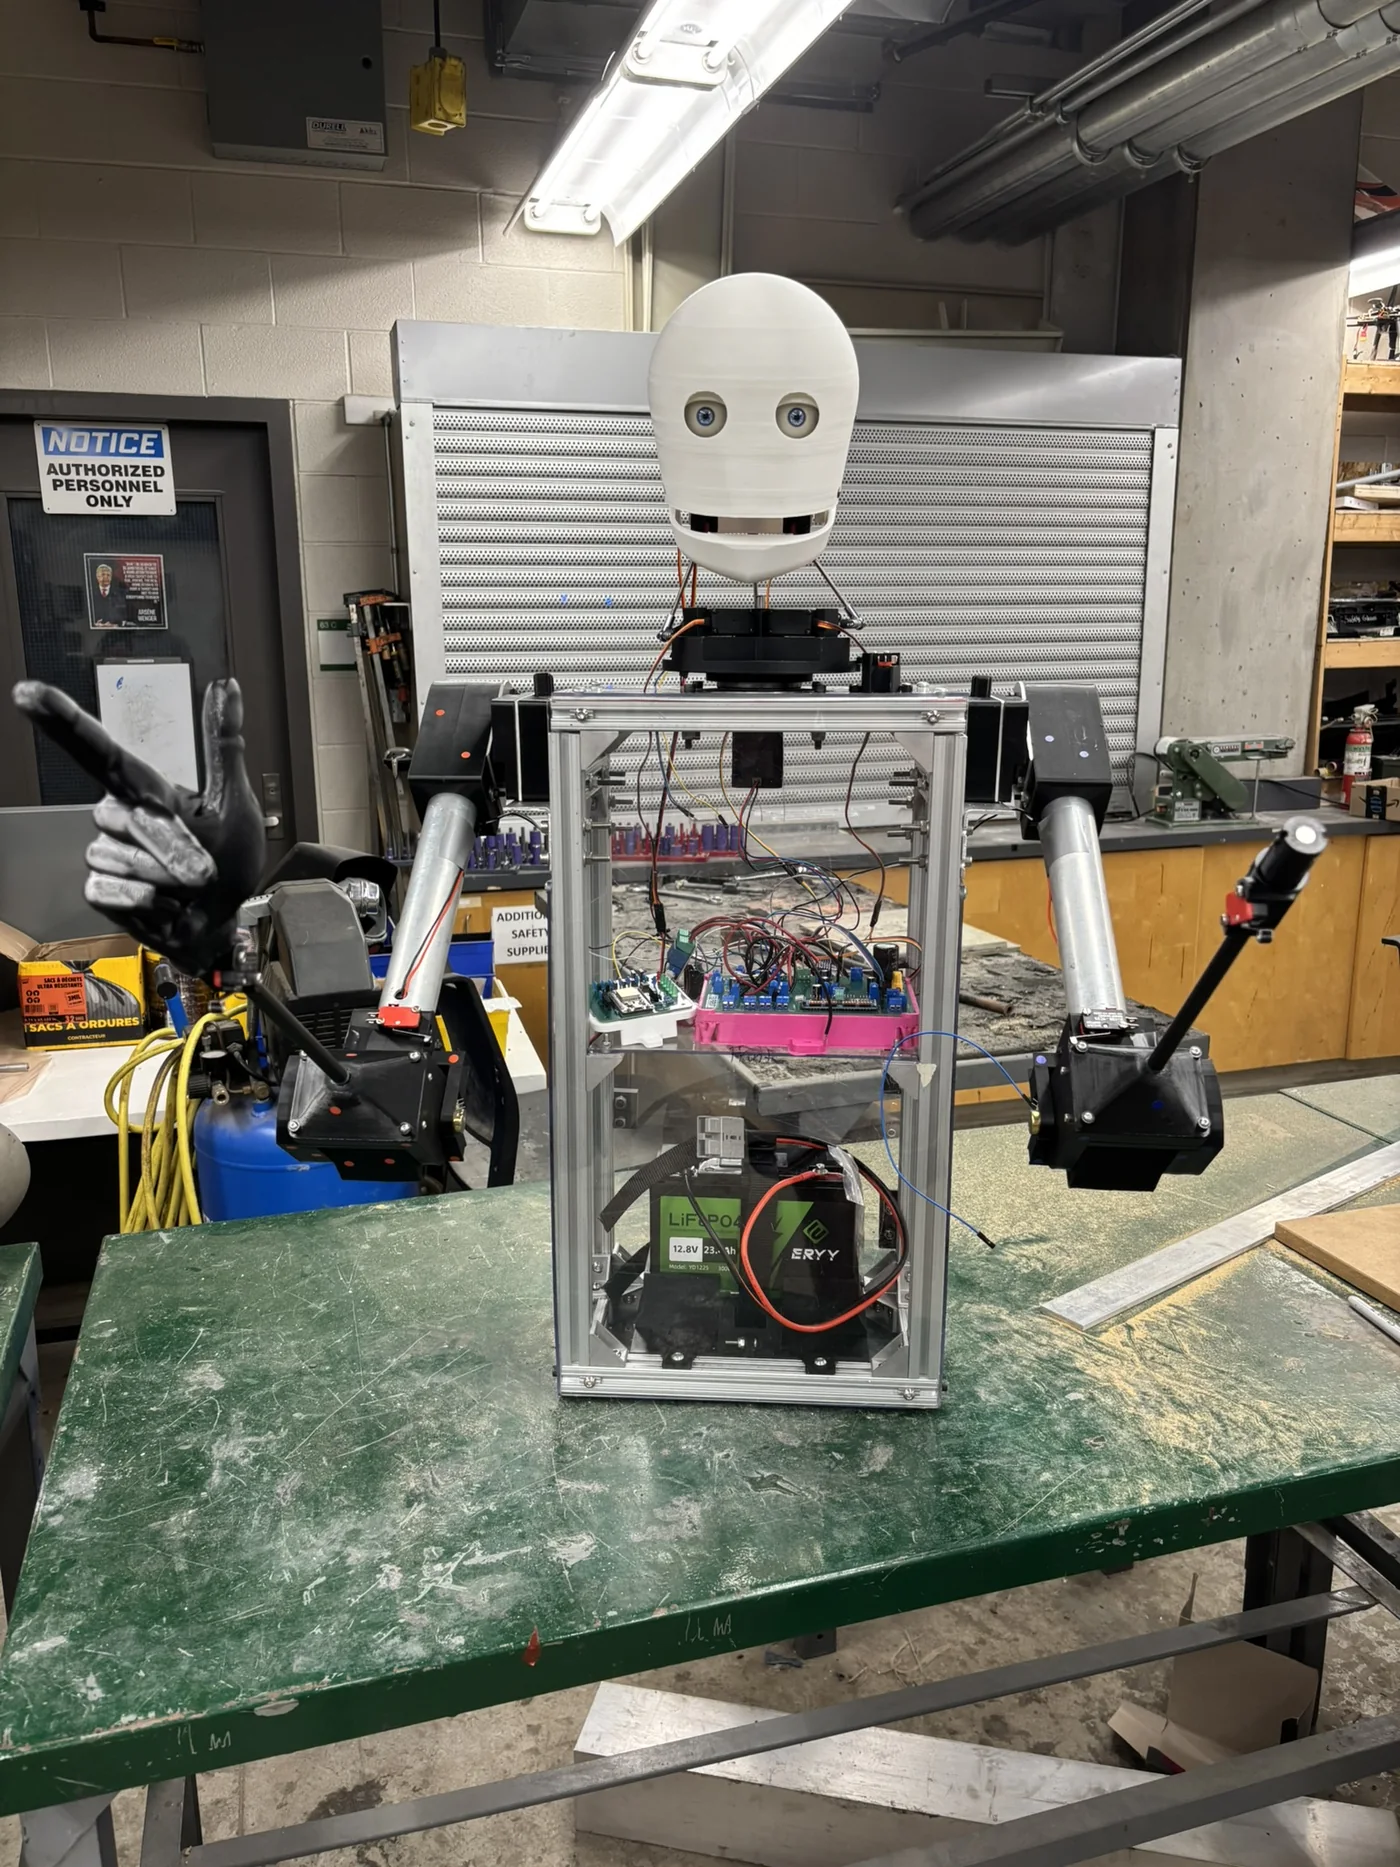
 Software integration in progress
Baker Bot
Leading a 12-person student build of an AI-enabled co-lecturer for Professor Baker, while independently developing the robot’s expressive head.
A working prototype, on a very real deadline.
Organizing a three-day robot build and leading the mechanical work, with hands-on development of the shooter and indexer.
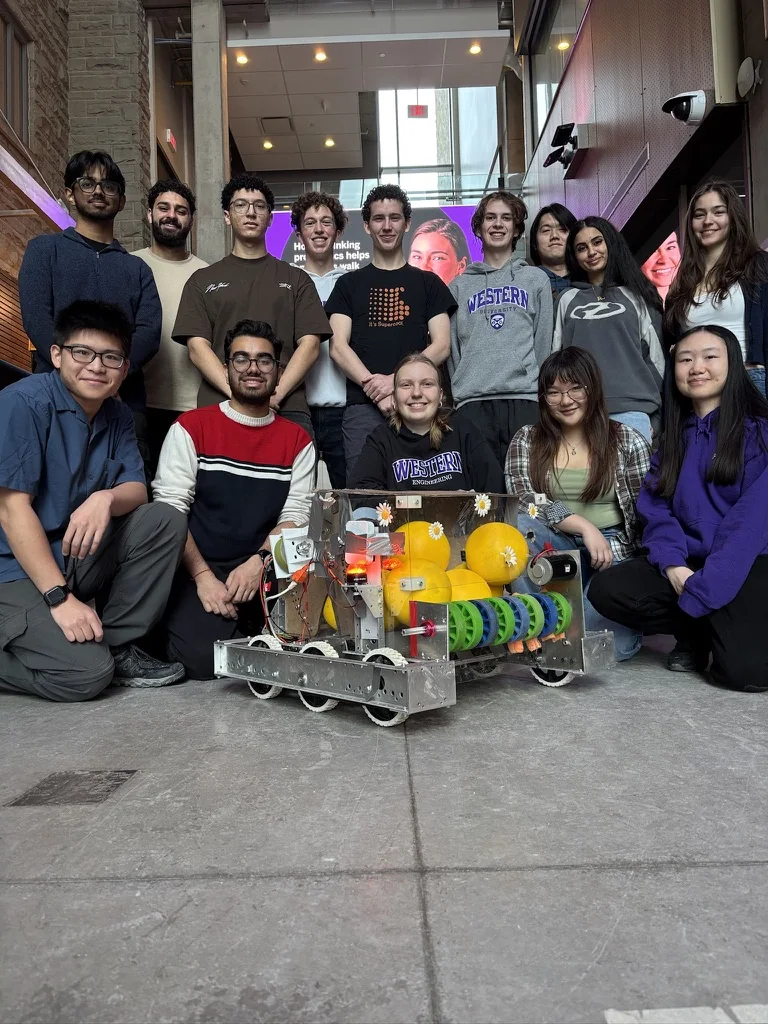
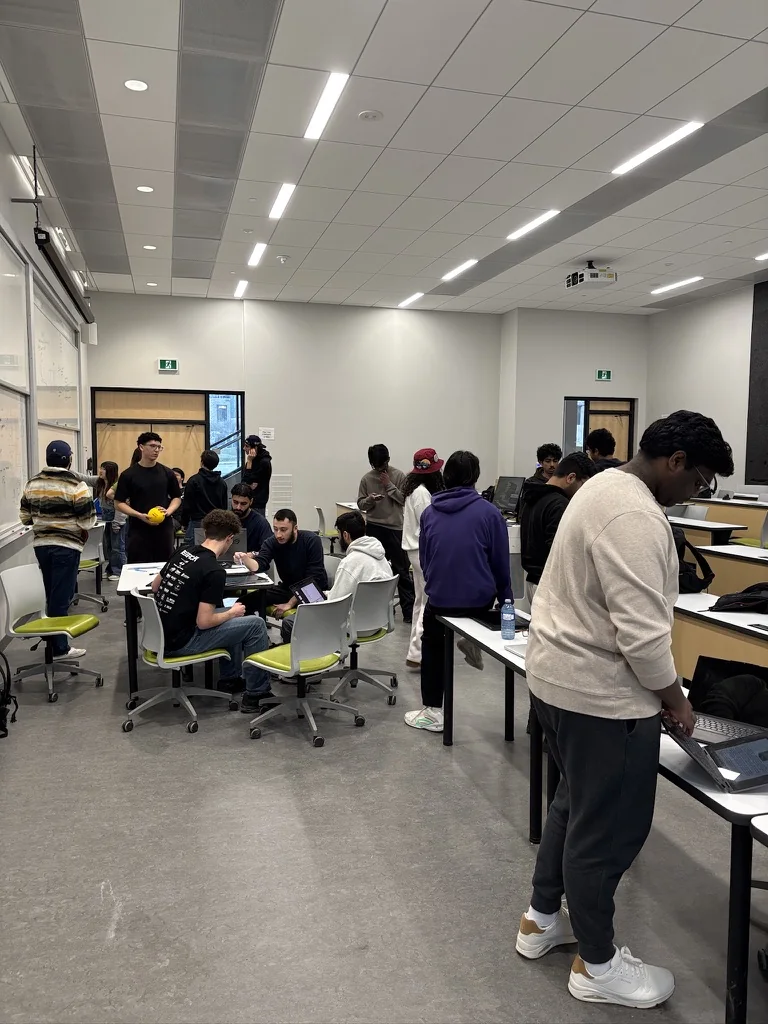
RI3D compresses a robot-development cycle into three days. I organized the event and led the mechanical systems while the team developed a functional prototype for the 2026 FIRST challenge.
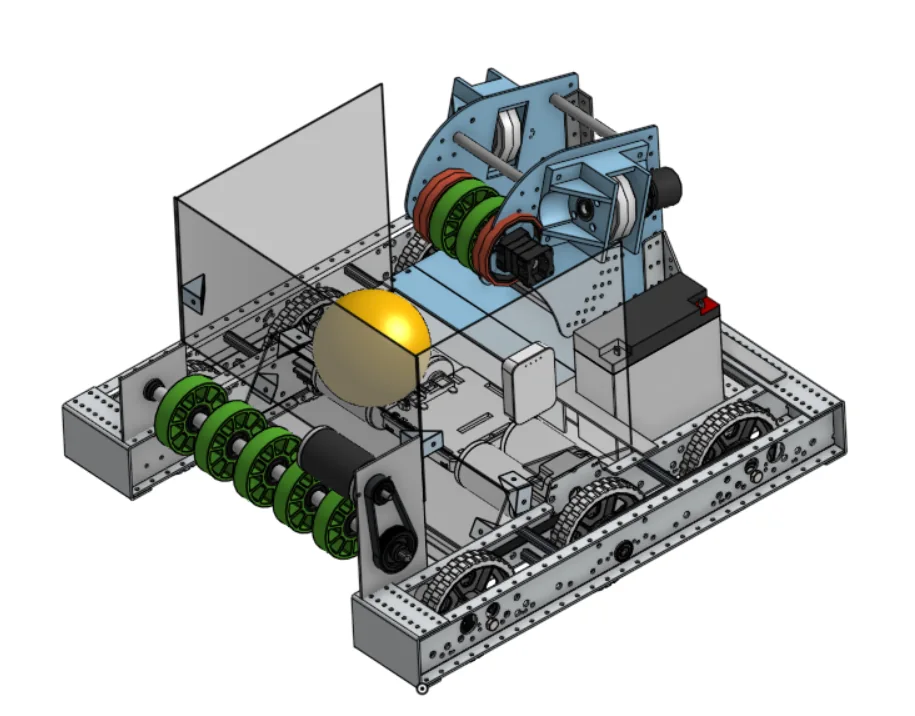
Moving balls from storage into the shooter reliably was one of the hardest problems. Balls would jam rather than funnel into the firing path.
We used guiding wedges to direct the balls into an indexer that pushed them into the shooter. The solution needed to work as a whole path, not just as separately functional mechanisms.
The shooter wheels needed enough contact to launch the ball, but too much compression prevented it from passing through.
We made multiple versions of the motor and wheel mounts to adjust their spacing. Rapid fabrication made it possible to test that fit and revise it inside the event’s time limit.
By the submission deadline, the robot could intake through a split-bumper intake, hold multiple balls, index and shoot them into the target hopper. The tank-drive arrangement could travel under the trench and over the field bump.
That result depended on mechanical, electrical and software teams bringing their work together. My technical contribution centred on mechanical leadership and the shooter/indexer; the full robot was a shared build.
The team demonstrated intake, storage, indexing, shooting and field traversal. The project was as much about choosing workable designs and integrating them on time as it was about any one mechanism.
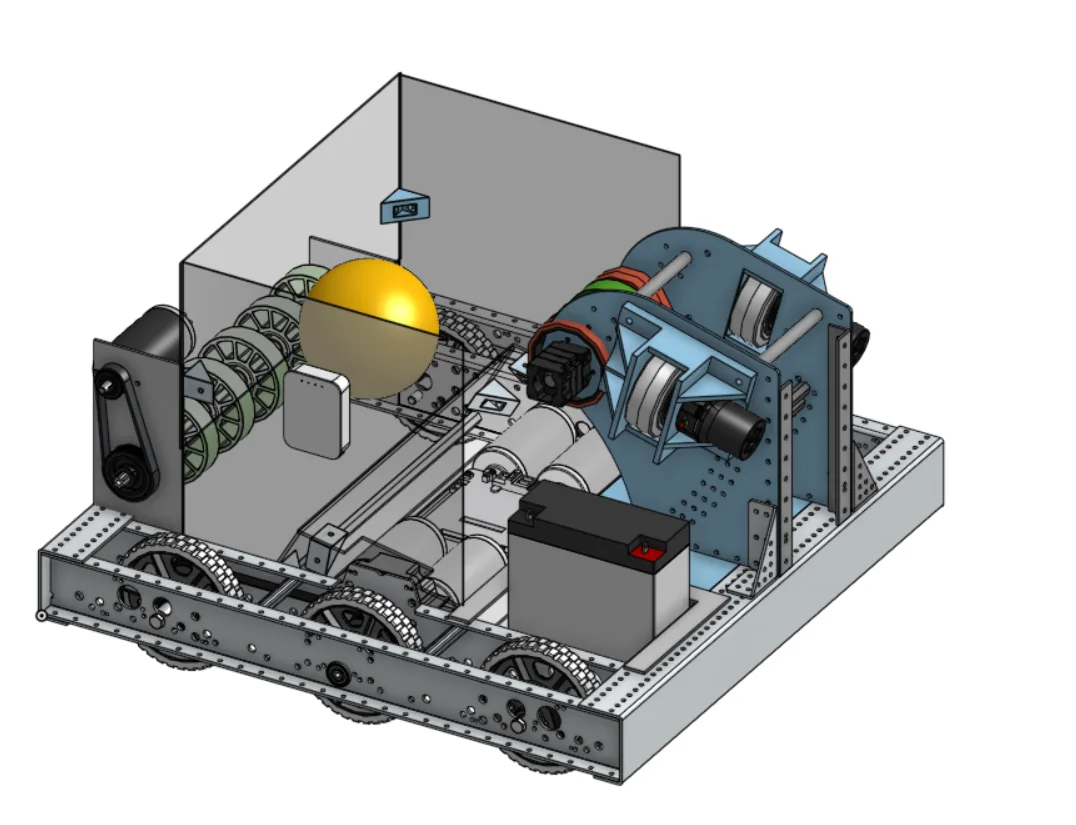
Detailed CAD with satin-metal and matte-polymer viewing materials. Slow rotation pauses when you interact; reduced-motion preferences are respected. Colours and finishes are for visualization.
 Software integration in progress
Leading a 12-person student build of an AI-enabled co-lecturer for Professor Baker, while independently developing the robot’s expressive head.
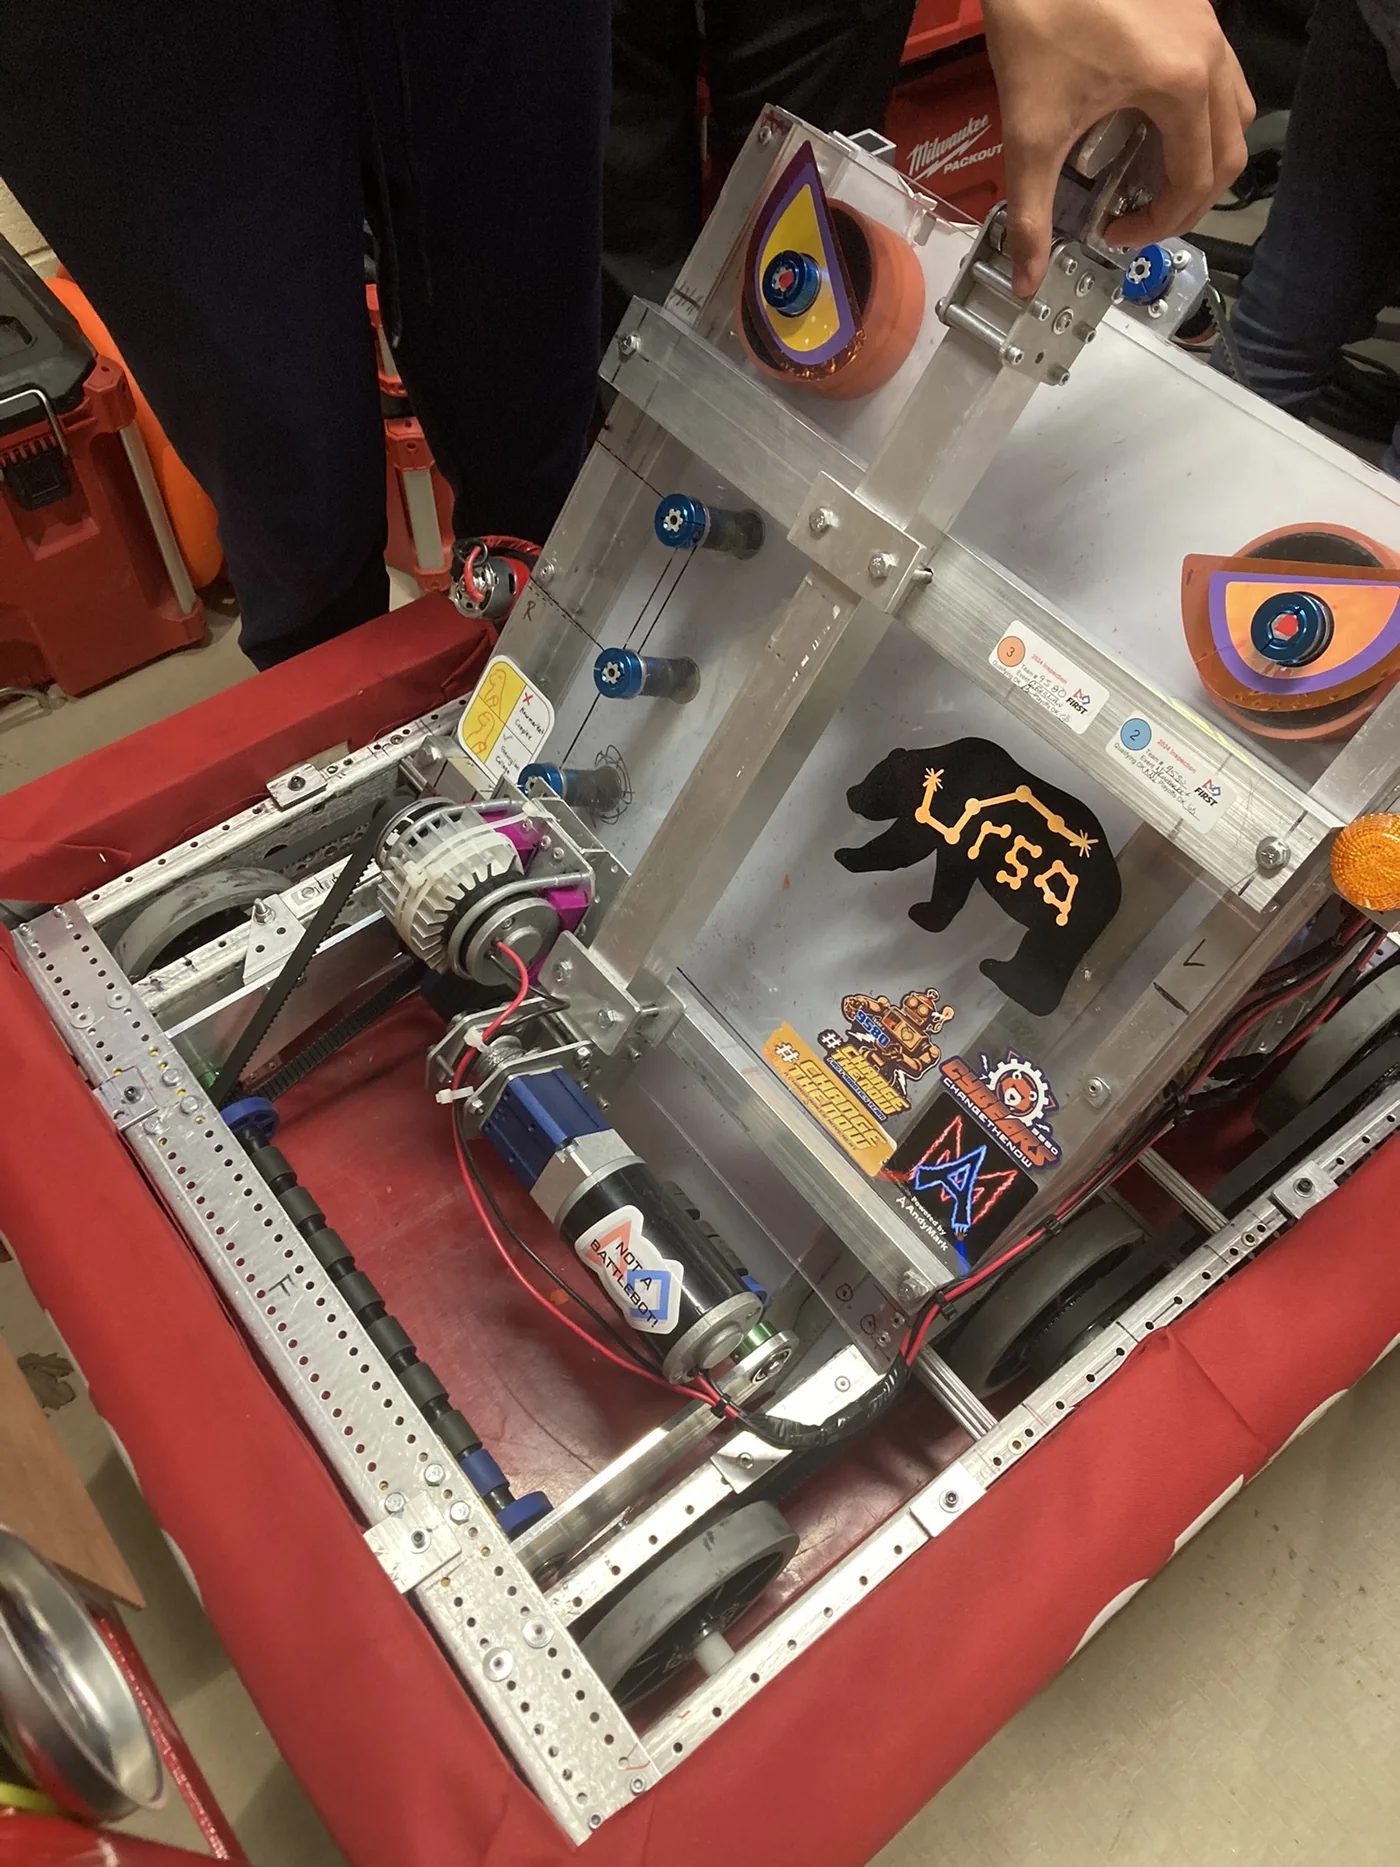 Season completed
Captaining a rookie FRC team, developing the under-bumper intake, and contributing substantial mechanical fabrication and electrical work.
 Completed placement
Mechanical upgrades, prototype iteration and installation coordination in an active automotive welding environment.